

Nippon Pulse
has provided a wide array of motion control solutions, including industry leading stepper motors, the innovative Linear Shaft Motor, controllers, drivers and networks.
A wide range of product offerings and expertise in application engineering makes NPM a discerning partner in motion control technology and implementation
Miniature AC servomotor with high torque and high-resolution
DDmotor has characterristics of low speed and high torque (compared to general servo motors) because this motor is assumed that it will drive directry without using a gear(a deceleration mechanism).
Its equipped sensor specialized in high-precision positioning, and It is possible to receive the shaft load directly by adopting high-load bearing as standard.
Advantages that can be generally obtained by using a gearless structure are described below.
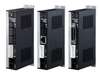
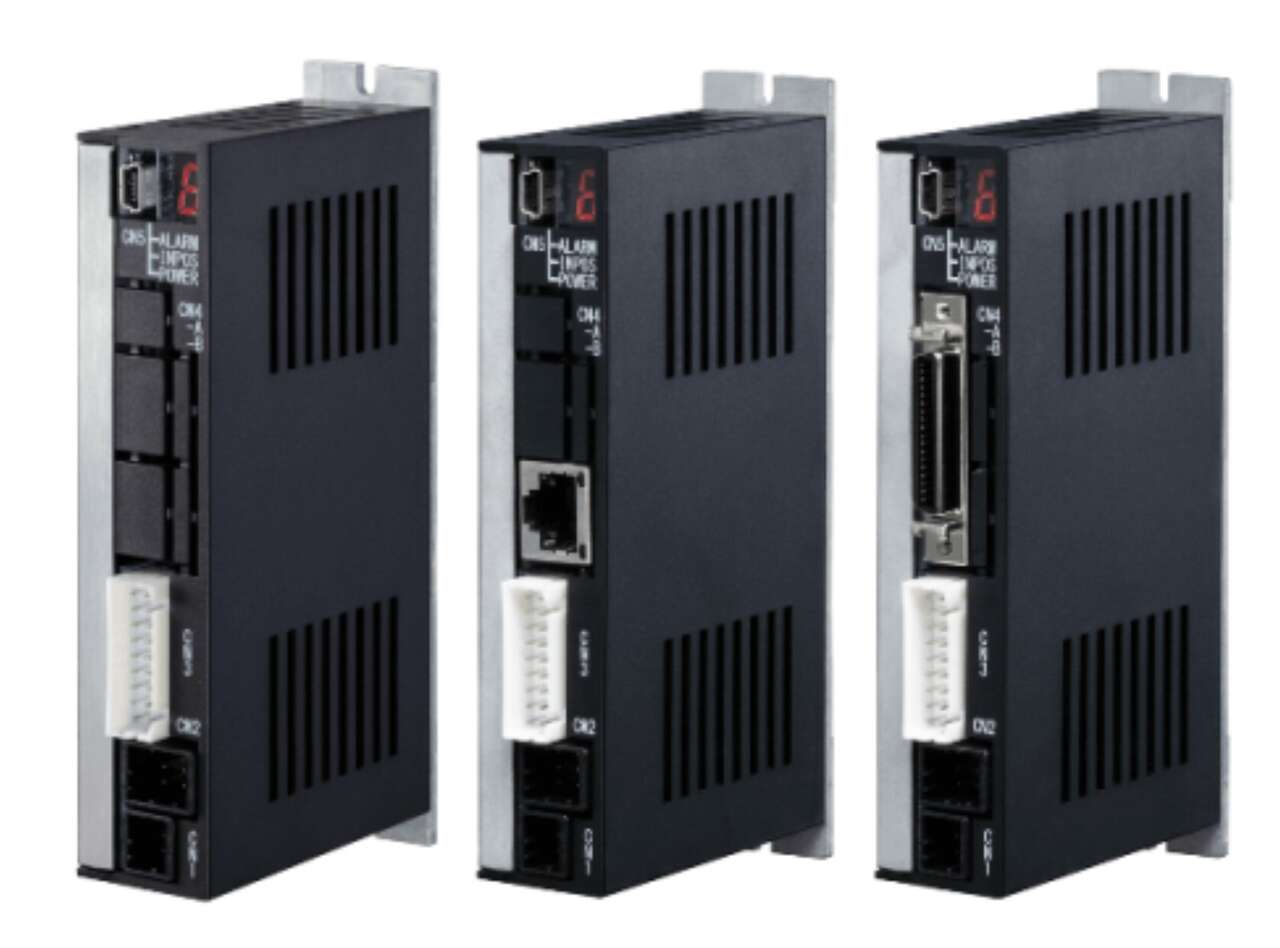
Servo driver
we selected a number of suitable drivers for the miniature Servomotors
.jpg)
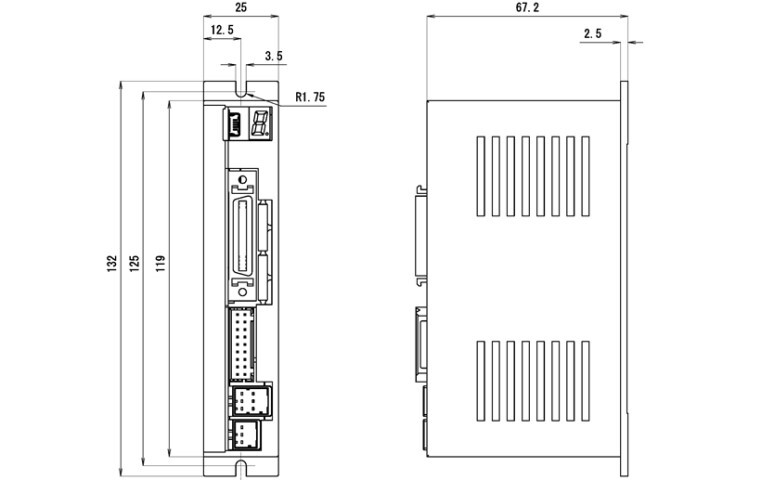
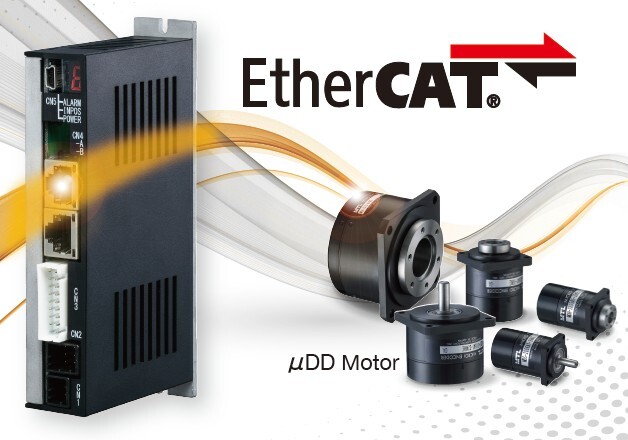
MC-200-7220B (EtherCAT)
| part nr. | MC-200-7220□ □→Blank: USB, A:I/O, D:SPI |
| Supply power | Rated DC48V (DC20V-5%~72V+5%) |
| Rated output current | 3.5 Arms |
| Peak output current(Less than 1 second) | 20 Arms |
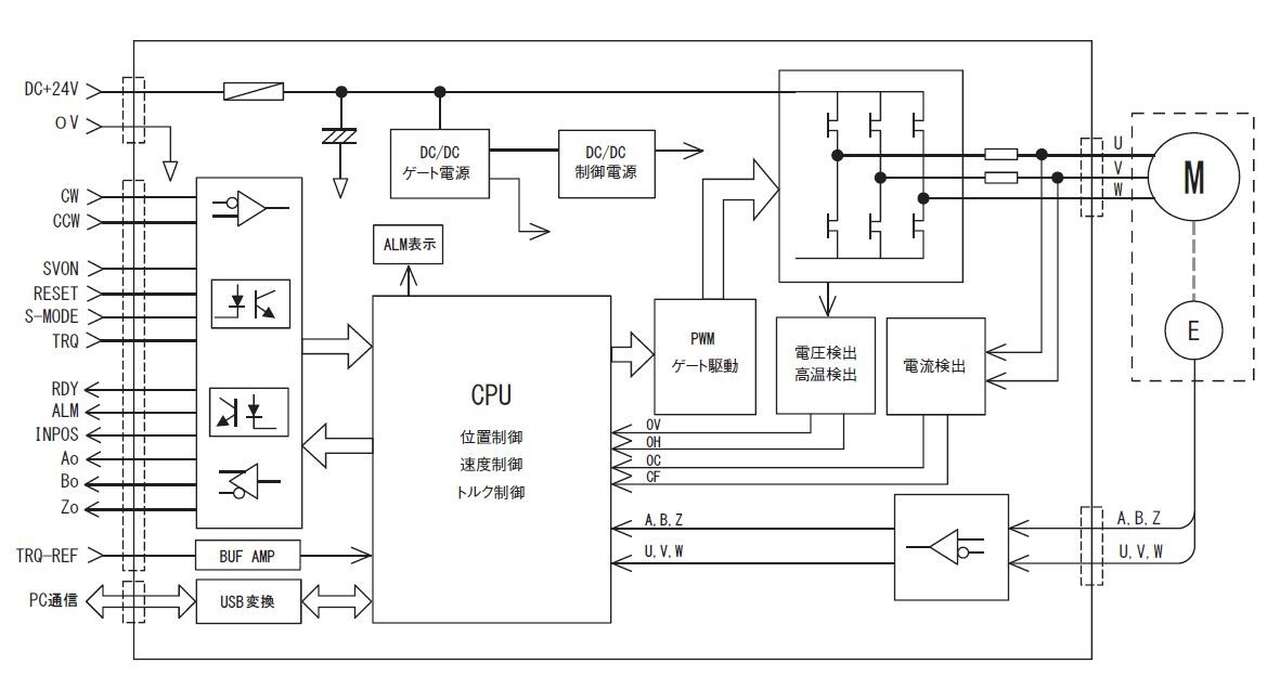
| Drive type | Sine wave PWM drive(50kHz) |
| Drive method | Position・Speed・Current control |
| Protection functions | Over current, overload, overvoltage, under voltage, heat,encoder error, prevention by fuse |
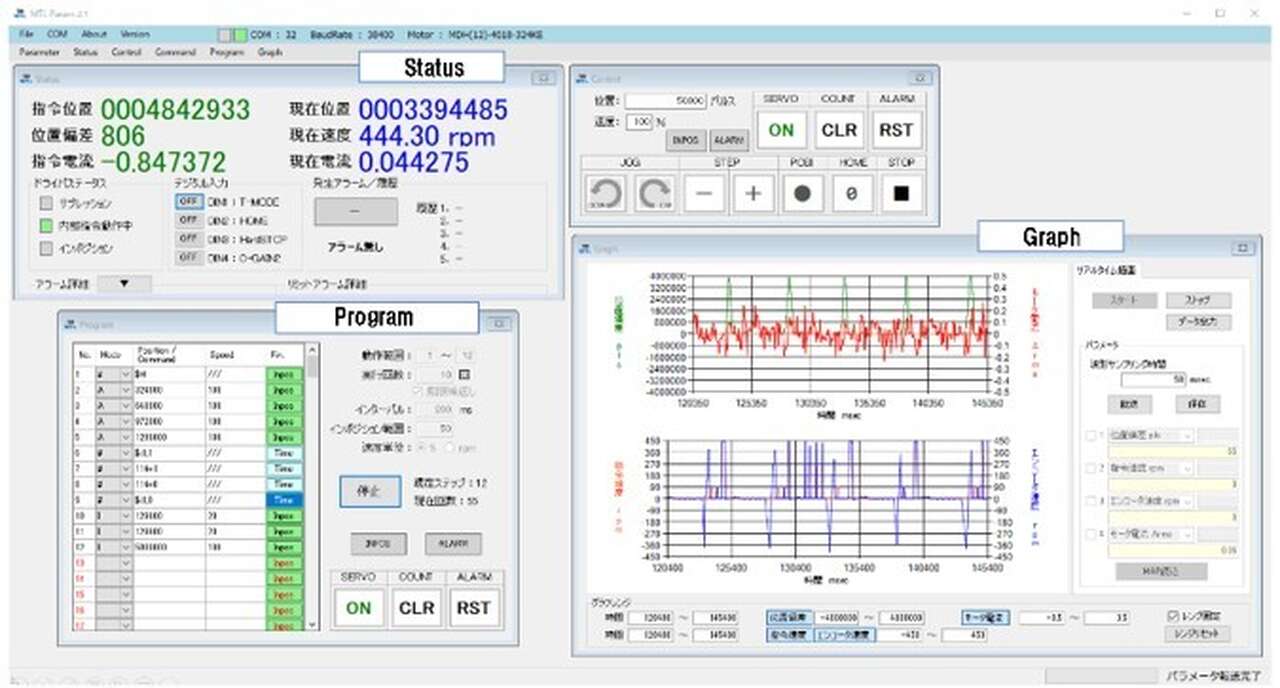
| Communication functions | USB2.0 mini-B parameter settings, status monitoring, command control |
| Speed position commands | driver:Maximum 2.5MHz(multiplied by 1) forward-reverse pulse train method/direction method, two-phase pulse method |
| Torque commands | Voltage command (-5 to +5V)12bit |
| Auxiliary signal inputs | Servo on, alarm reset, Gain switch, zero point return, other general-purpose inputs |
| Signal outputs | Positioning completed, alarm, analog monitor output (current/speed/position difference) encoder (Incremental:ABZ、Absolute:RS422 ASCII code、binary code) |
| Command method | I/O, SPI, USB and other soon |
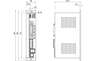
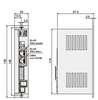
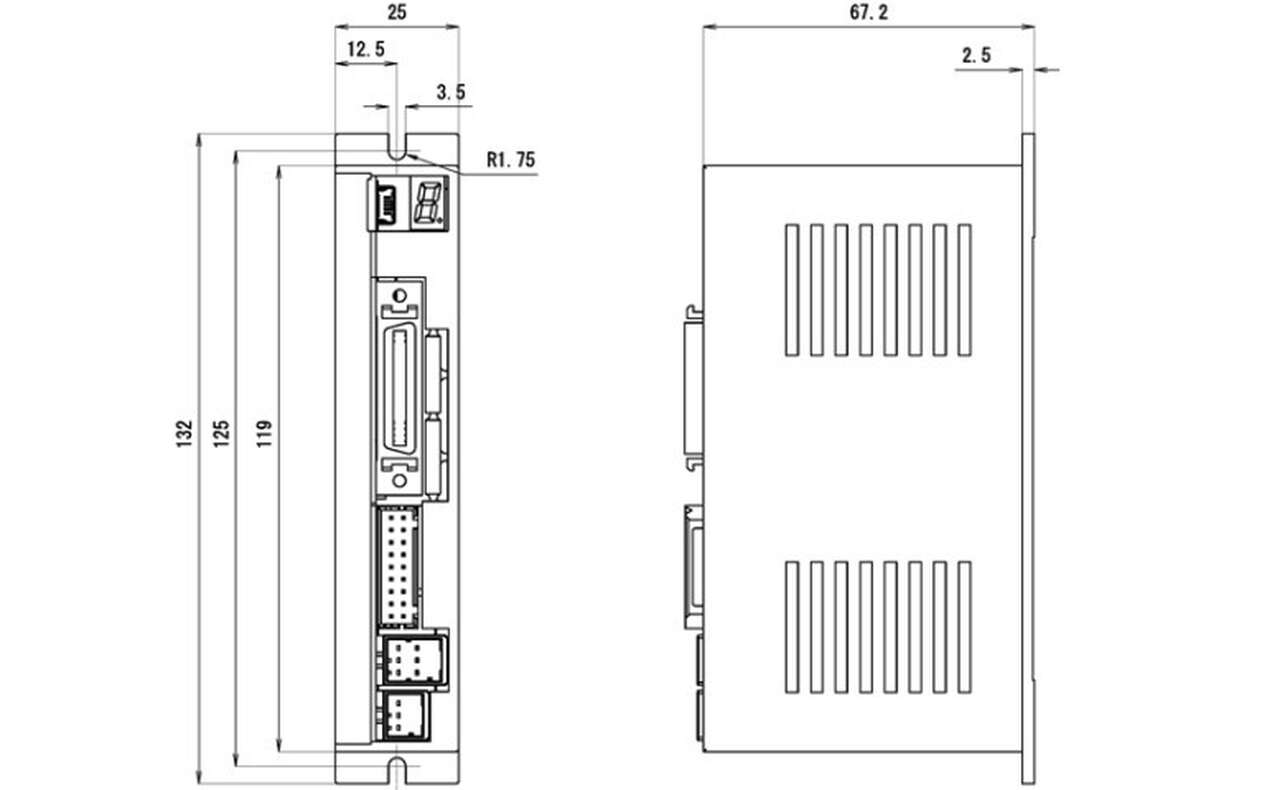
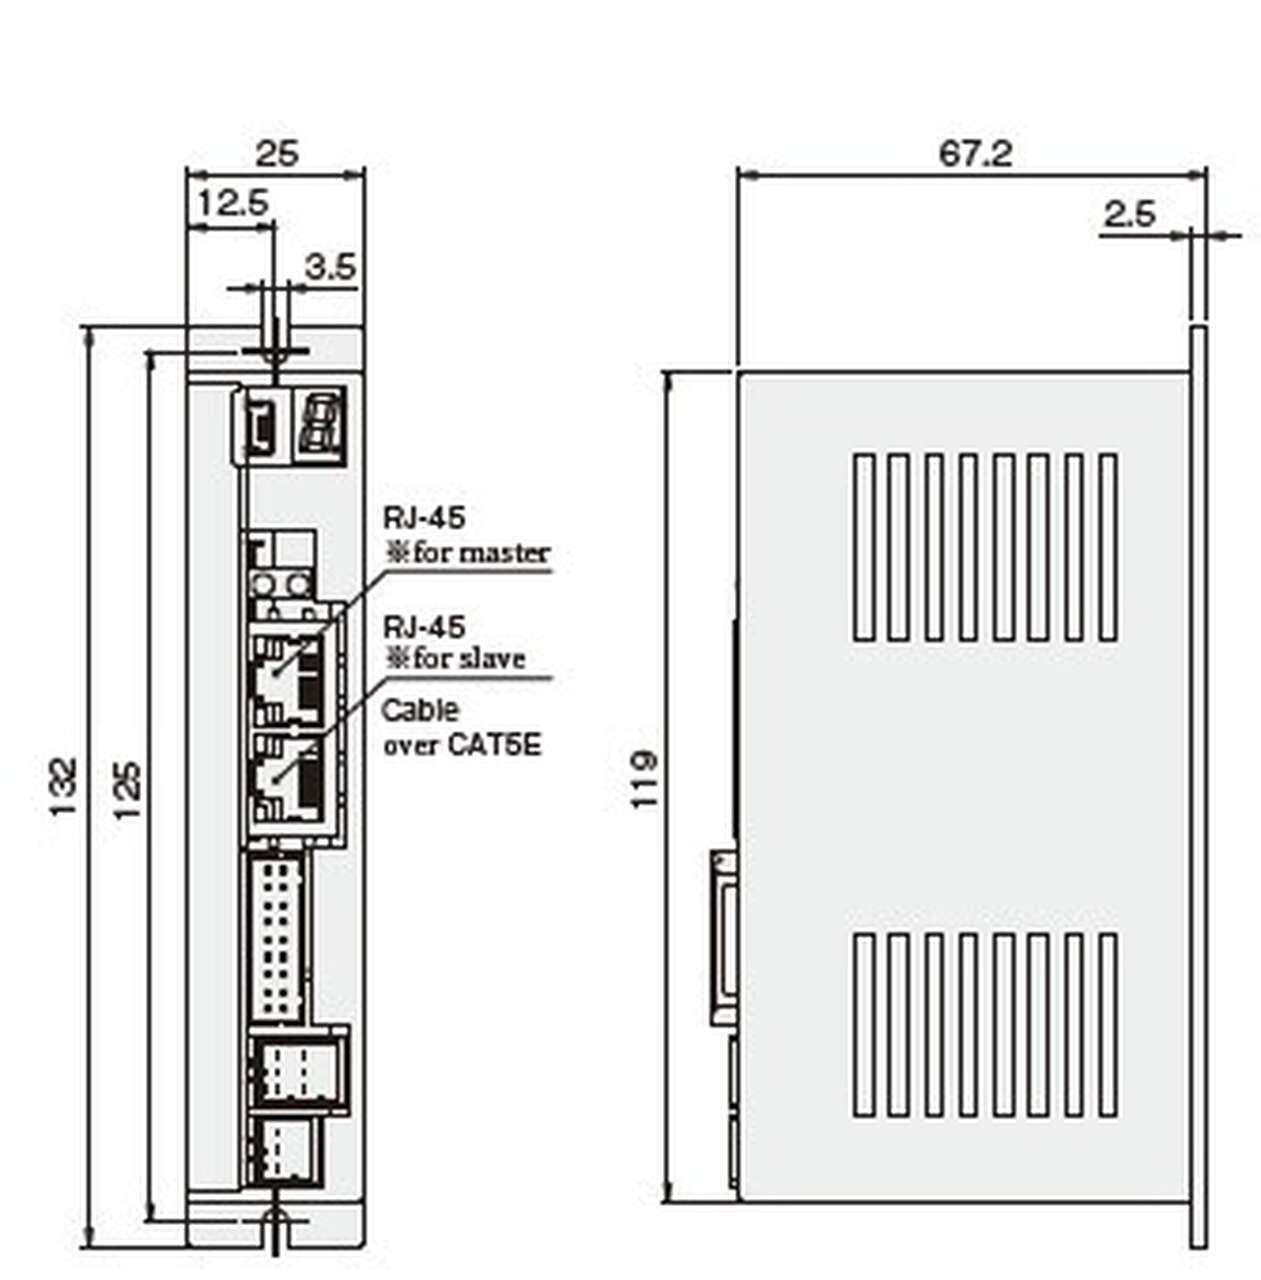
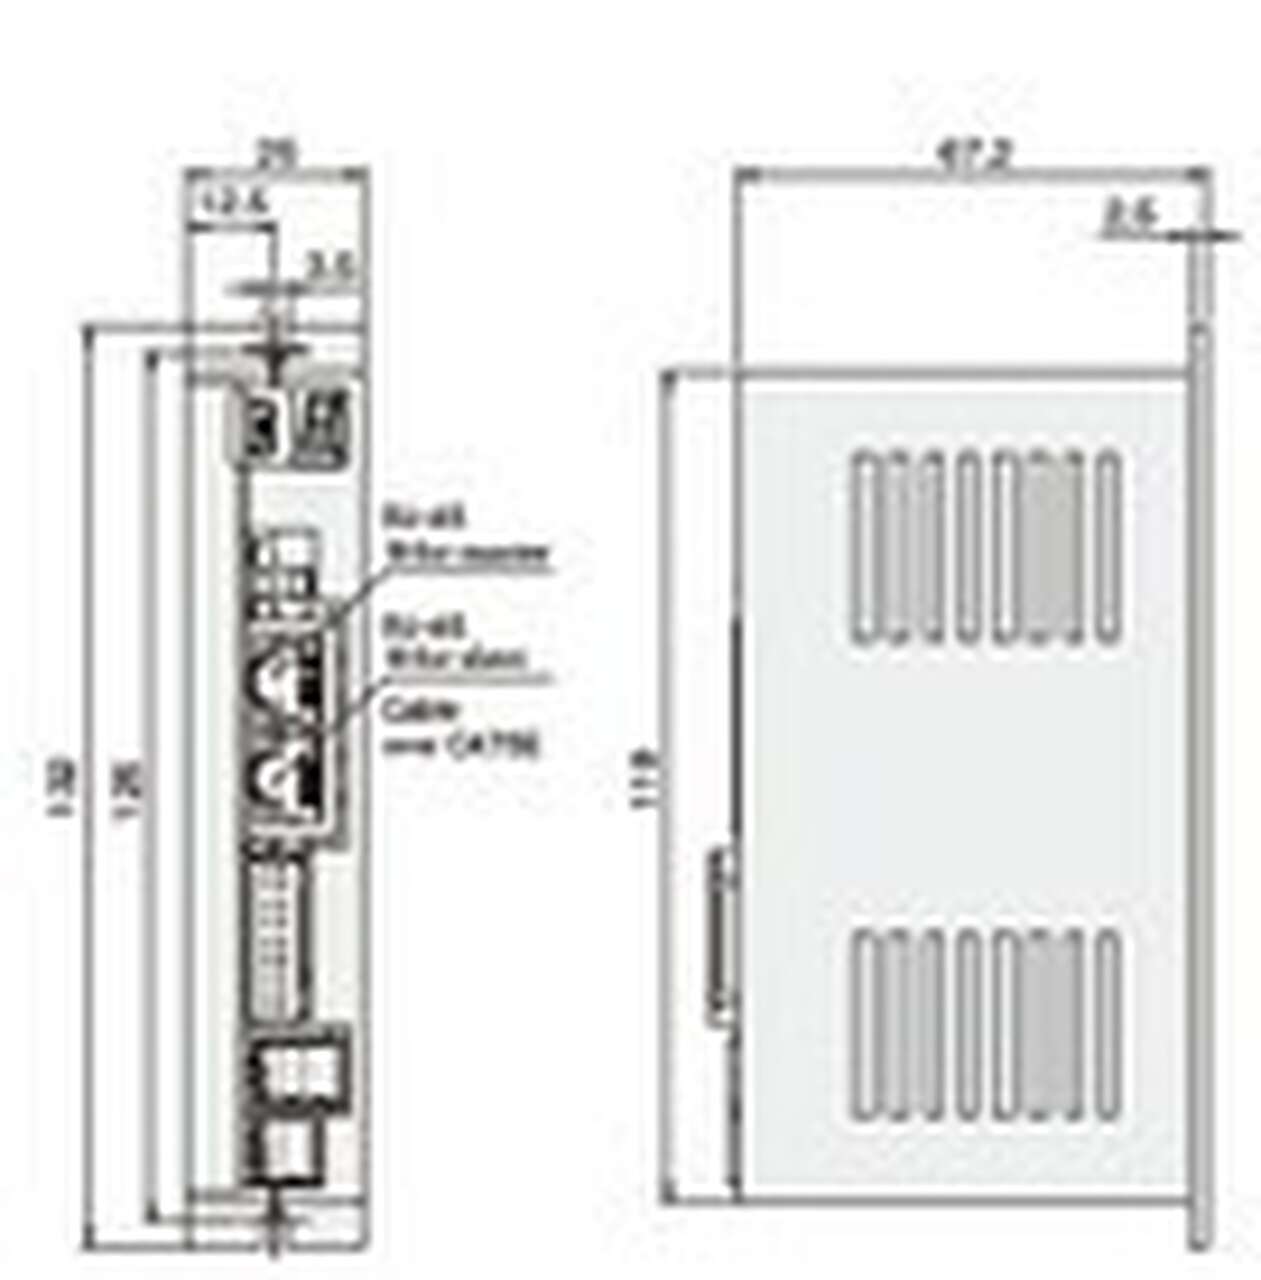
| External dimensions | 132×67.2×25mm |
| Mass | 160 g |
| External command method | Supports EtherCAT CiA402 drive profile (select version -7220B |
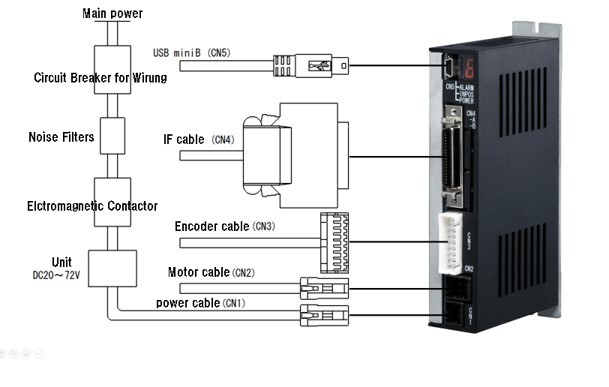
options:
Cables
Model | Connection |
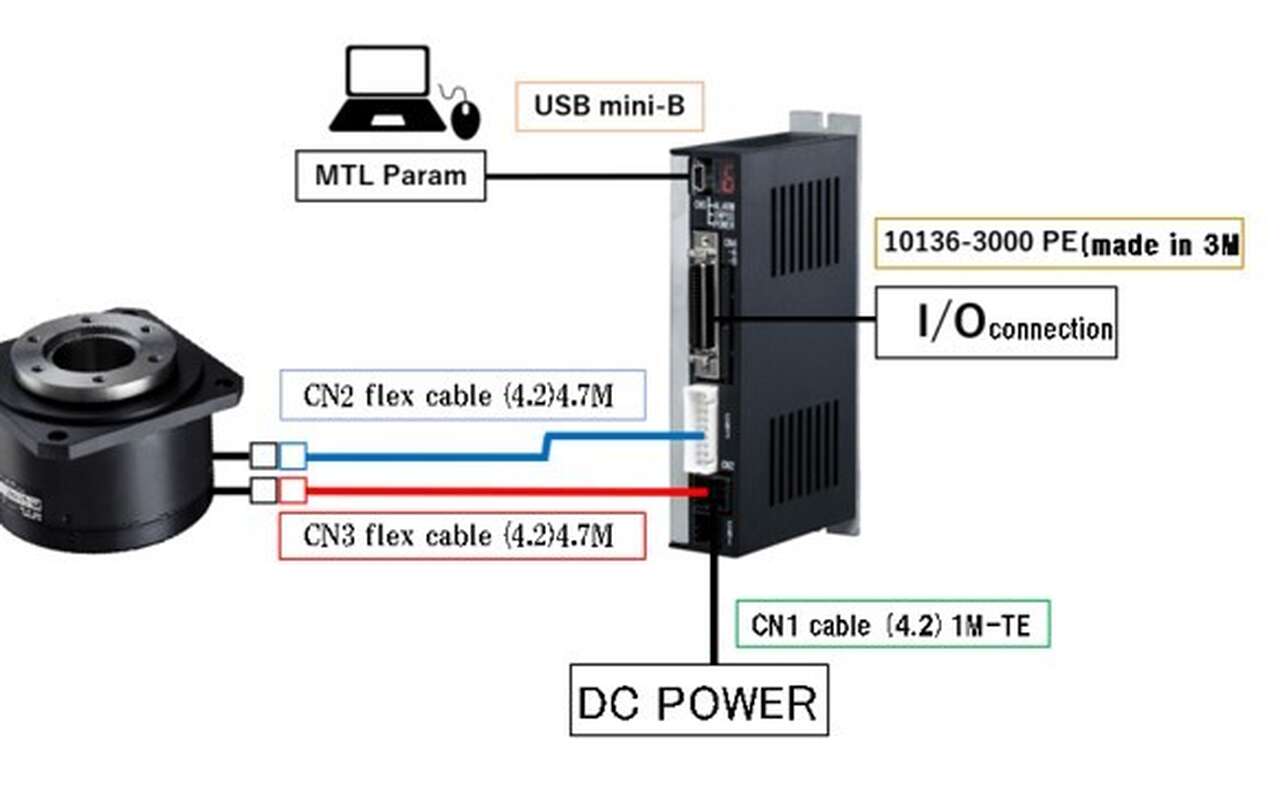
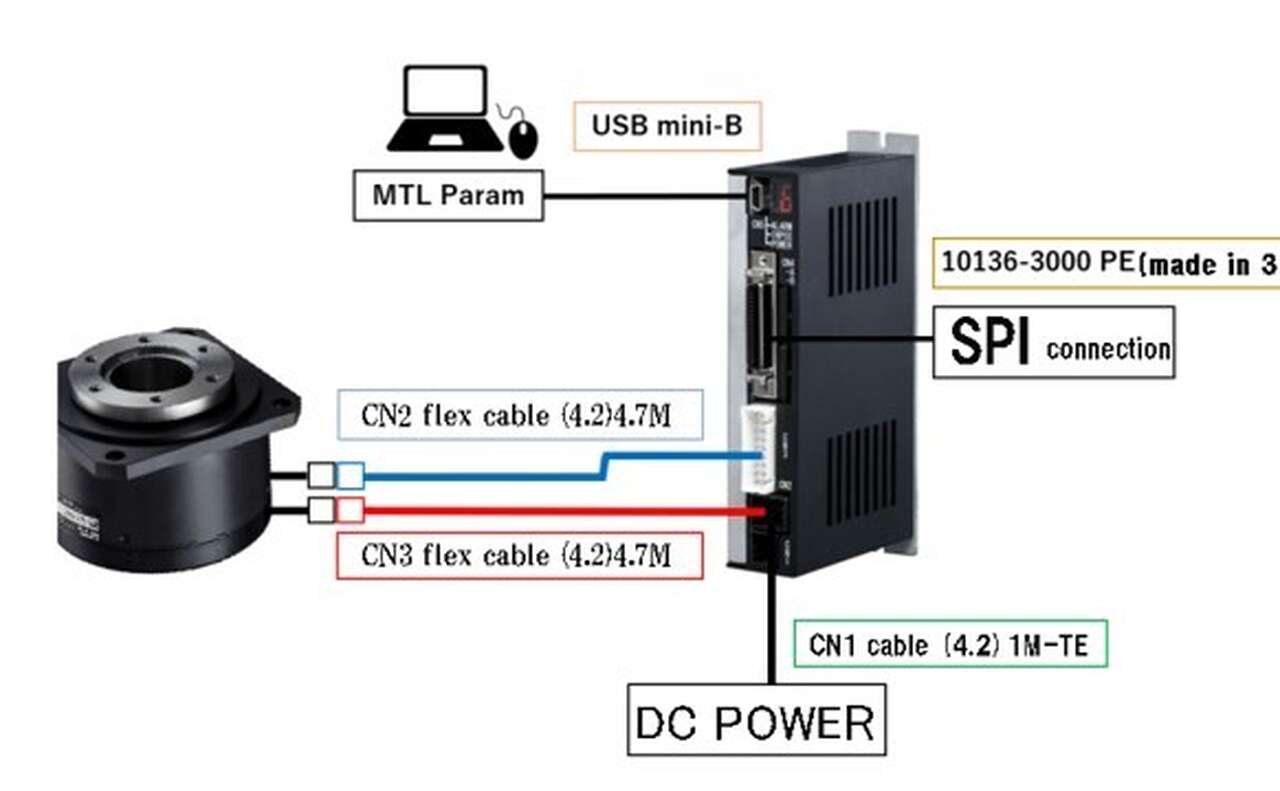
CN1 cable(4.2)1M-TE | Between power and driver(1m) |
CN2 bent cable(4.2)0.7M | Motor cable:Extension between motor and driver (Total1m) |
CN2 bent cable(4.2)2.7M | Motor cable:Extension between Motor and Driver(Total3m) |
CN2 bent cable(4.2)4.7M | Motor cable:Extension between motor and driver(Total5m) |
CN3 bent cable(4.2)0.7M | Encoder cable : Extension between motor and driver(Total1m) |
CN3 bent cable(4.2)2.7M | Encoder cable : Extension between motor and driver(Total3m) |
CN3 bent cable(4.2)4.7M | Encoder cable : Extension between motor and driver(Total5m) |
CN5 cable | USB2,0 cable with ferrite core : Between PC and driver(1m) |
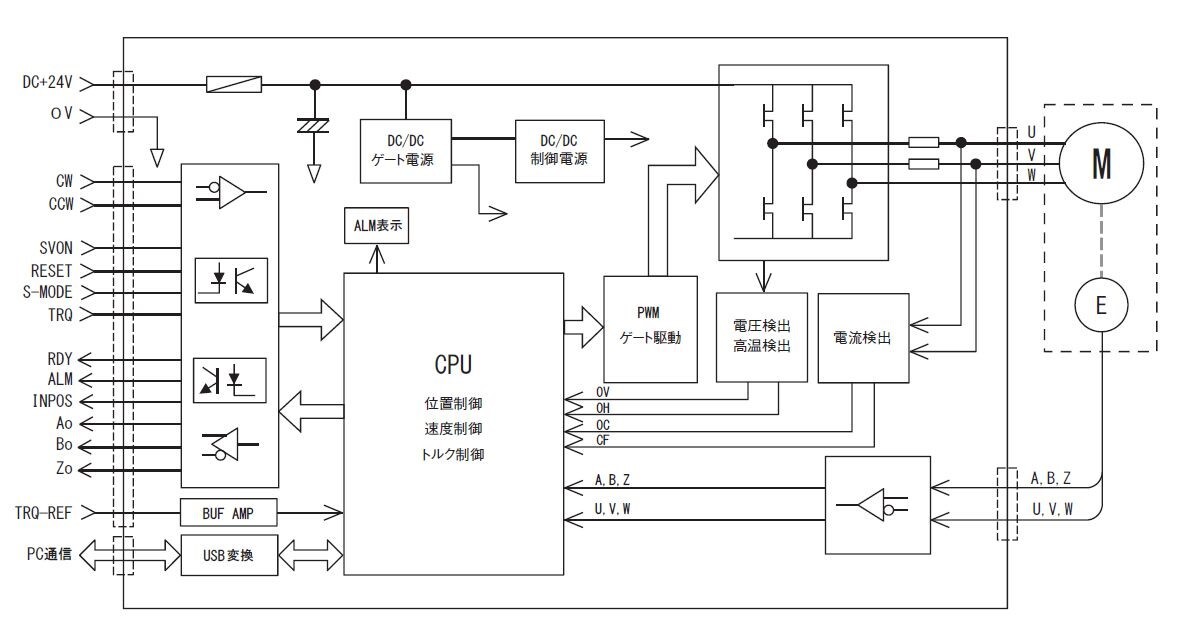
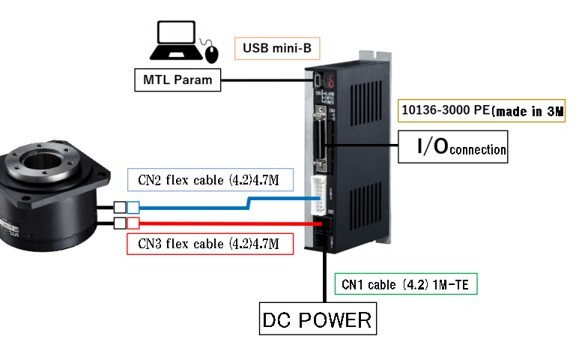
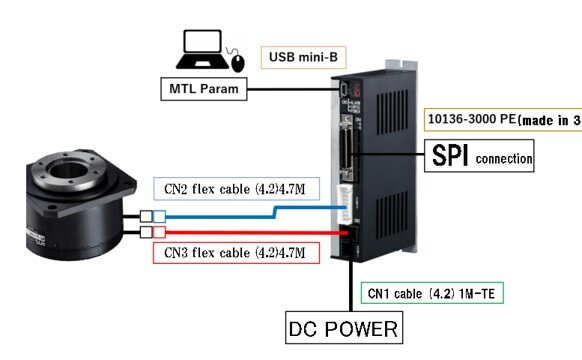
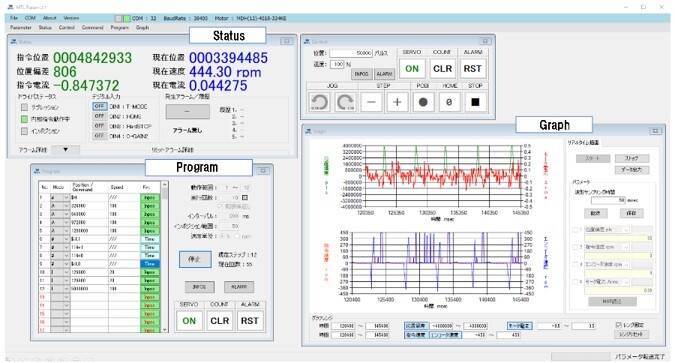
Parameter setting, status monitoring, command control are possible.
The program function allows each drive control by a driver only.
We collected the following documentation as PDF-File, that you can access by clicking on the icons.
If you have searched for info but is not listed, or not completely answering your requirements, perhaps the document you are looking for is not public.
In that case, please contact us by using the following means: